LiDAR technology has become a key tool for capturing information about terrain and objects with a precision that sounded like science fiction just a few years ago. Today, we find it in mapping projects, environmental studies, archaeology, and even in helping autonomous cars and domestic robots navigate. All of this is thanks to a system that fires pulses of light and measures, with incredible accuracy, how long it takes for that light to travel to the surface and back.
At the same time, LiDAR has managed to displace more traditional measurement methods in many sectors because it allows for the generation of highly detailed 2D and 3D models of large areas in a very short time. In this guide, we'll see exactly what LiDAR is, how it works, what types of systems exist, how its data is processed, what file formats are used, and in which fields its full potential is being realized.
What is LiDAR and why is it so important?
LiDAR stands for Light Detection and Ranging , an active remote sensing technique that works by emitting laser light pulses and detecting their return. Unlike passive systems (such as many satellite cameras), LiDAR emits its own signal and does not depend on sunlight, allowing it to operate both day and night.
The underlying physical principle is simple: a pulse of light is emitted, and the time it takes to return after reflecting off an object or the ground is measured. Using this time and knowing the speed of light, the system calculates the distance traveled by the pulse. Repeated hundreds of thousands or millions of times per second, this process generates millions of points with X, Y, Z coordinates, forming what is known as a 3D point cloud.
One of the most powerful features of LiDAR is its ability to partially penetrate vegetation . Depending on the wavelength, firing frequency, and pulse energy, part of the signal can pass through the tree canopies and reach the ground. This allows scientists to determine not only the shape of the terrain but also the vertical structure of the forest (canopies, trunks, understory, etc.), which is vital for forestry and ecological studies.
When a laser pulse reaches the ground, it impacts a small area known as a footprint . Within this footprint, there can be several reflective surfaces: leaves, branches, roofs, bare soil, water, etc. Each of these surfaces generates a return echo. Therefore, a single pulse can produce a single return or several sequential returns. The number of echoes and their intensity depend on the type of surface and the distribution of vegetation or infrastructure.
Compared to other remote sensing technologies, LiDAR offers very high spatial resolution and altimetric accuracy , with errors of only a few centimeters when the system is properly calibrated. This ability to map terrain and objects in such detail has driven its use in high-resolution mapping, urban planning, infrastructure management, and advanced mobility applications.
Basic components and operating principle of LiDAR
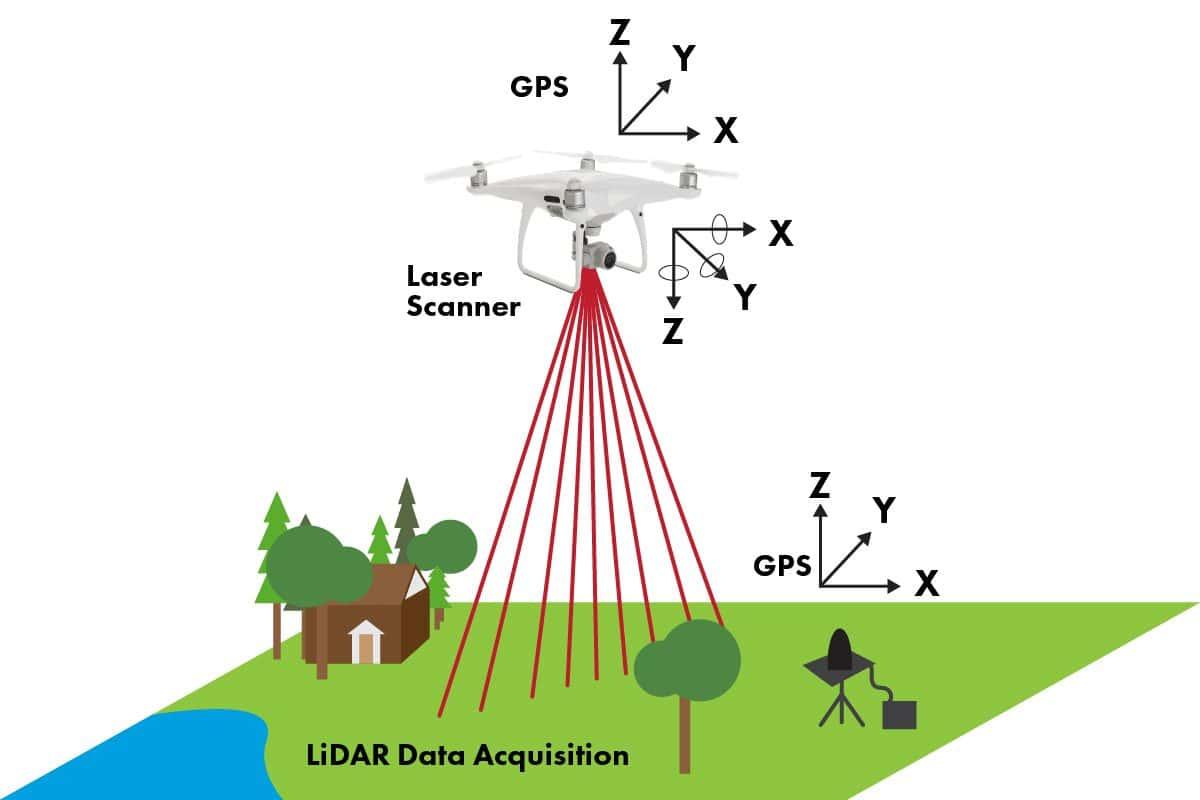
Every LiDAR system is built around a set of highly coordinated electronic and navigation components . The goal is to know, with enormous precision, both the sensor's position and the direction in which each pulse points, as well as the exact time it takes to return.
Essentially, a LiDAR system integrates a laser emitter, an inertial measurement unit (IMU), a high-precision GPS receiver, and a control interface connected to a computer. The laser emits pulses in the ultraviolet, visible, or, very commonly, near-infrared range (for example, around 1064 nm). In some specialized systems, the green band is used to penetrate water and measure bathymetry (depth) and the characteristics of the seabed or riverbed.
The system works based on the well-known Time of Flight (ToF) method . The sensor records the instant the pulse is emitted and the instant the echo returns. The distance is calculated with a very simple formula: distance to the object = (speed of light × time of flight) / 2. The factor of 2 comes from the fact that the pulse travels both ways.
As the laser fires pulses, the GPS receiver determines the system's position in X, Y, Z coordinates , and the IMU measures its orientation (pitch, yaw, roll). Combining all this data, it becomes possible to know, for each pulse, where it was emitted from, where it was pointing, and the distance of each return; that is, the three-dimensional position of each point in the cloud.
Modern LiDAR systems are capable of firing hundreds of thousands or even close to a million pulses per second . By repeating the process over and over as the sensor moves (on an airplane, a drone, a car, a rotating tripod, etc.), a high-definition 3D model of the environment is built, with a point density that allows for the detection of very fine details.
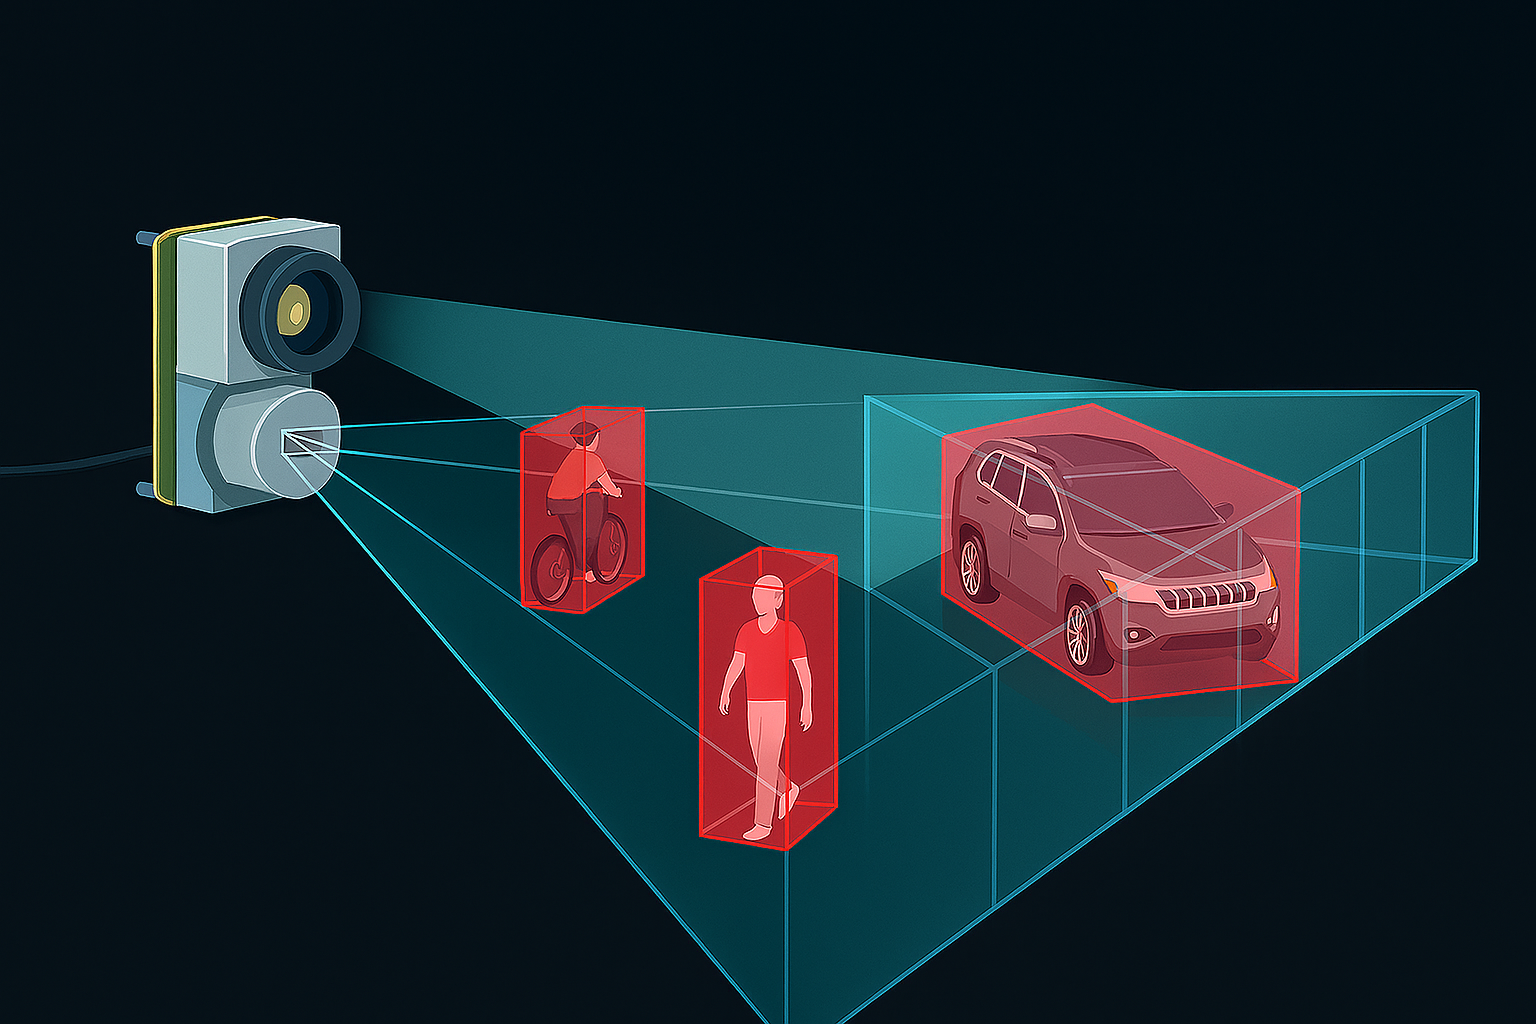
In the fields of mobility and robotics, this acquisition speed, combined with an accuracy of a few centimeters, makes LiDAR ideal for detecting obstacles and calculating distances in real time . It is the foundation for autonomous vehicles to anticipate curves, pedestrians, or road features, or for robots to move around a home without bumping into furniture and walls.
Classification of points in LiDAR clouds
Once captured, a LiDAR point cloud is simply a vast collection of millions of uninterpreted 3D points. Each point can and should be labeled according to the type of surface that reflected the pulse : ground, buildings, low, medium, or high vegetation, water, etc. This labeling process is called point classification.
In standard LiDAR files, each point can be associated with a numerical classification code that indicates which category it belongs to. These codes are standardized by the American Society for Photogrammetry & Remote Sensing (ASPRS) for the LAS format, so that different programs and organizations can exchange data while maintaining the same classification logic.
In real-world mapping projects, such as those carried out on autonomous communities, classification typically begins by separating points on the ground from points belonging to elevated features (buildings, trees, infrastructure, etc.). From there, categories can be refined to obtain digital terrain models (ground only) and digital surface models (ground plus all objects on it).
This classification work is mostly done using automated analysis algorithms that apply filters and geometric rules (for example, identifying continuous, smooth surfaces like floors, or vertical blocks like buildings). However, in complex areas or areas with automated errors, manual editing is still common, reviewing and correcting points one by one or in groups.
For reliable classification, the capture parameters must be carefully considered : sensor flight altitude, scanning angle and direction, flight line axis, overlaps between passes, pulse density per square meter, etc. All of these factors influence the density and distribution of the point cloud and, therefore, the final quality of the generated models.
LiDAR file formats: LAS and LAZ
In the professional world, almost all LiDAR systems and applications use the LAS format as a de facto standard . LAS is a public specification developed by ASPRS specifically for exchanging three-dimensional point clouds from LiDAR sensors.
The LAS format is a binary file designed to store all relevant information from the LiDAR system , maintaining both the coordinates of each point (X, Y, Z) and a set of additional attributes. Being binary and normalized, it allows for the efficient handling of large volumes of data and compatibility between software from different manufacturers.
For each point stored in a LAS file, it is possible to save not only its position, but also information such as the intensity of the return, the return number (first, second, last…), the total number of returns generated by that pulse , the classification value, the flight pass identifier, the color (red, green and blue components), the GPS timestamp, the scan angle and the scan direction, among other fields.
When data volumes are enormous, which is very common on regional or domestic flights, LAZ is used, which is simply a compressed version of LAS . LAZ maintains the logical content of LAS but in a lossless compressed binary file, which considerably reduces file size and facilitates storage, transmission, and download.
In official projects, such as those covering thousands of square kilometers, it is common to organize LAS/LAZ data in a grid of regular tiles (e.g., 2 × 2 km grids), so that it is easy to locate, process and update specific areas without always having to work with a single gigantic file.
Real-world example: LiDAR flight and capture characteristics
To better understand how a campaign is planned, we can look at the case of a LiDAR flight carried out over a Spanish autonomous community , where laser capture was combined with oblique aerial photography in both RGB color and near infrared.
In that project, the coverage area was just over 5.000 km² , corresponding to the entire autonomous region. The average capture density was set at approximately 2 pulses per square meter, sufficient for mapping and terrain analysis applications at a regional scale.
The flight was conducted during a specific period (e.g., September 2016), seeking suitable atmospheric conditions (clear skies or very high cloud cover, low levels of fog or dust, etc.) to maximize the quality of the return data. The geodetic reference system used was ETRS89, with ellipsoidal altitudes referenced to the GRS80 ellipsoid, which facilitates integration with other European geospatial sources.
The accuracy achieved was remarkable: horizontal RMSE (root mean square error) values were around 20 cm in X and Y, and overall altimetric accuracy in Z was on the order of 15 cm. In addition, aerial photography with a resolution of 0,50 m and red, green, blue, and near-infrared bands was taken, providing very useful information to complement the LiDAR analysis.
The data were organized into 2 × 2 km blocks in LAS format , allowing each area to be processed independently, batch processing to be run, and computational resources to be adjusted. This tiled structure is already a de facto standard in many national and regional remote sensing projects.
Methodology for processing and generating digital models
The work doesn't end when the plane or drone stops flying; in fact, a critical part of the project is processing the LiDAR files to generate useful end products: digital terrain models, surface models, vegetation maps, change analysis, etc.
Many professional workflows utilize specialized tools like LAStools, a suite of command-line utilities from Rapidlasso GmbH optimized to take advantage of multiple CPU cores. These utilities allow for highly efficient point cloud cleaning, filtering, sorting, merging, and conversion, and are ideal for integration into batch processing scripts.
To coordinate tasks and automate complex processes, it's common to integrate these tools within ETL (Extract, Transform, and Load) platforms like FME from Safe Software. In these environments, you can design visual workflows, launch LAStools commands, call Python scripts, and manage large amounts of files in a structured way.
In a typical case, the initial data is in ellipsoidal heights referenced to ETRS89 . From there, transformations can be applied to obtain orthometric heights (relative to the geoid) or to adapt the data to other reference systems if the project requires it. It is also in this phase that the automatic classification of points (soil, vegetation, buildings, water, etc.) is performed, following a predefined task scheme.
The processing results typically materialize in digital terrain models (DTMs) and digital surface models (DSMs) , as well as other derived products such as slope maps, relief shaded areas, 3D building models, and visibility analyses. All of these rely on the LiDAR point cloud, which has been properly filtered, classified, and transformed.
Technical advantages of LiDAR compared to other sensors
One of the reasons LiDAR has become so popular is that, operating in the optical band, it offers a resolution far superior to that of many microwave radars. The laser's operating frequency is two to three orders of magnitude higher, resulting in extremely high range, angular, and velocity resolution.
Furthermore, the laser beam has a short wavelength and a very small divergence angle , meaning it can concentrate its energy in a very small area and minimize the effects of multiple paths (those unwanted reflections that can confuse microwave or millimeter-wave sensors). Thanks to this, LiDAR is able to reliably detect targets located at low or very low altitudes and in complex urban environments.
Another key advantage is that LiDAR doesn't rely on ambient light to function . The system emits its own laser beam and obtains information about the target from the echo signal of that same beam. This allows it to operate 24 hours a day, in sunlight or complete darkness, and regardless of changes in light that would affect conventional optical cameras.
In terms of design, traditional microwave radar systems are typically bulky, with antennas that can reach several meters in diameter and equipment masses measured in tons . In comparison, many LiDAR sensors are much more compact and lightweight, with sizes that can be as small as a few centimeters, making them easier to integrate into drones, vehicles, robots, or even wearable devices.
In addition, the internal architecture of LiDAR is relatively simple compared to other complex radar systems, resulting in easier maintenance and simpler operation for the end user. All of this makes it a very attractive tool for industrial and field applications.
Types of LiDAR systems according to the platform
LiDAR is not a single, closed technology, but rather a set of systems that adapt to different platforms. Generally speaking, three main types of systems are distinguished according to where the sensor is mounted : airborne, terrestrial, and satellite or space-based.
Airborne LiDAR is installed on airplanes, helicopters, or drones. It is the most widely used for regional and national mapping because it allows for covering large areas in a relatively short time. From the air, high-resolution terrain models can be obtained, changes in topography detected, vegetation analyzed, and infrastructure planned with a very high level of detail.
Ground-based LiDAR is mounted on moving vehicles (cars, vans, trains) or on static tripods. In mobile mode, it is used, for example, to scan streets, railway lines, or tunnels, while in static mode it is ideal for documenting facades, building interiors, archaeological sites, or infrastructure with very high resolution.
Finally, satellite or space-based LiDAR is placed aboard satellites or orbiting platforms. These systems cover very large areas, on a continental or global scale, although with lower resolution than airborne or ground-based systems. Even so, they are essential for climate studies, large-scale biomass analysis, and monitoring global changes.
In all cases, the philosophy is the same: to generate point clouds that describe the geometry of the environment , adapting the resolution, point density and capture platform to the specific needs of the project and the desired working scale.
LiDAR applications in different sectors
The list of LiDAR applications is long and grows every year. In the fields of cartography and geography, it is used to create high-resolution altimetric maps , generate terrain models for civil engineering projects, analyze flood risks, assess slope movements, and study river dynamics.
In archaeology, LiDAR has gained particular renown because it allows researchers to "see" beneath dense vegetation , revealing structures, ancient roads, and settlements that go unnoticed in traditional aerial photographs. In tropical forests, for example, it has been key to discovering ancient cities hidden beneath the jungle.
Forestry and natural resource management also benefit greatly from this technology: LiDAR can be used to estimate tree height, biomass volume, canopy structure and forest density , which helps with harvesting planning, fire prevention and habitat conservation.
In disciplines such as seismology, mining, geology, and wind farm optimization, the precise 3D models provided by LiDAR facilitate the study of faults, exposed subsurface structures, slopes, quarries, and terrain conditions . It is also a key tool for environmental impact studies and landscape restoration projects.
In atmospheric physics, specific LiDAR systems are used to analyze aerosols, clouds, and atmospheric layers , measuring, for example, particle concentration profiles or the heights of thermal inversion layers. This is very useful for meteorology, pollution monitoring, and climate studies.
LiDAR, robotics and autonomous driving
For years, LiDAR was a technology widely used in geosciences but relatively unknown to the general public . That changed with the expansion of consumer robotics and the rise of autonomous vehicles, which brought these types of sensors to the forefront of media attention.
In mobile robotics, LiDAR is a fundamental component because it allows the machine to perceive its environment in 3D : detecting walls, furniture, people, or other obstacles, calculating distances, and generating internal maps of the space. This connects with SLAM (Simultaneous Localization and Mapping) algorithms , which allow a robot to locate itself while building a map of the area it is moving through.
In the field of autonomous driving, LiDAR systems mounted on cars and other vehicles provide constant scanning of the road and its surroundings . They detect other vehicles, pedestrians, curbs, signs, medians, and any potential obstacles, providing the control system with a high-definition 3D map on which to make split-second decisions.
Beyond cars, LiDAR technology has found its niche in areas such as virtual and augmented reality (VR/AR), smart transport, ocean exploration, fisheries resource monitoring, and even 3D printing , where geometric precision is key to faithfully capturing or recreating objects and environments.
Advanced LiDAR sensors and new dToF solutions
The evolution of electronic components has led to very compact and specific direct time of flight (dToF) LiDAR solutions for applications such as point measurement, collision detection or small 3D scenes.
A representative example can be found in development kits based on silicon photomultiplier (SiPM) technology . These kits integrate into a single device the near-infrared laser diode, the SiPM sensor, the optics, and the digital processing necessary to transform the echo signal into flight times and, subsequently, into distances.
SiPM sensors offer extremely high detection efficiency and very short response times , overcoming some of the limitations of conventional photodiode-based solutions. The device generates histograms of photon arrival times, allowing for better discrimination of useful signals from noise and accurate measurements at ranges from approximately 10 cm to over 20 m, depending on the specific design.
This type of dToF platform is used in applications such as distance measuring, anti-collision systems, parking sensors, and short-range 3D mapping . They are usually accompanied by dedicated graphical user interfaces (GUIs) for configuring parameters, visualizing data, and experimenting with different use cases.
The rapid advancement of these technologies, coupled with growing demand in sectors such as automotive, Industry 4.0, robotics, and consumer electronics, means the LiDAR market is booming . Increasingly, new sensor variants are appearing, tailored to specific needs, ranging from large airborne systems to miniaturized modules that can be integrated into compact devices.
Perspectives and role of LiDAR in the coming years
Given everything we've seen, it's no wonder that LiDAR has become an almost indispensable technology for mapping, monitoring, and evaluating surfaces and objects with high precision. Its advantages over other sensors—high resolution, high accuracy, day and night operation, and good performance in complex environments—make it a very solid option for a multitude of projects.
Use cases in cartography, archaeology, forestry, conservation biology, atmospheric science, mining, geology, and renewable energy have amply demonstrated its practical value . At the same time, the emergence of robotics and autonomous mobility has popularized it among the general public, extending its presence far beyond academic or institutional settings.
Everything suggests that in the coming years we will continue to see LiDAR sensors become cheaper, miniaturized, and integrated into more devices , multiplying their applications. From small domestic robots to large Earth observation programs, light-based detection and measurement is on its way to becoming a standard component of the technological ecosystem.